|
Jaime A. Romero I'm a graduate student at the University of Pennsylvania GRASP Lab, pursuing my Master's in Robotics. Currently working at Whoop as an ML engineer on their Sensor Intelligence Team. Previously, I worked at General Motors on autonomous vehicle fleet systems and electric vehicle components. I completed my B.S. in Mechanical Engineering with a minor in Robotics at Carnegie Mellon University. |
|
Research InterestsI'm focused on building safe, intelligent robotic systems for everyday environments. My work combines:
|
Projects |
|
Importance Neurons: Does an LLM's MLP Encode How Hard It Will Fight for a Goal?
Jaime A. Romero Mechanistic Interpretability, 2026 An interactive mechanistic-interpretability report on persistence—how many times a model re-attempts a staked riddle ("solve this and you get a Ferrari / save 10 lives") before giving up—and whether the activation energy (CETT) of specific MLP neurons on the opening prompt predicts it. The report toggles the full analysis across three models, combining a linear-probe regression, an L1-logistic context-fill classifier, a preference-vs-persistence choice experiment, activation steering, and a raw-conversation viewer. In gemma-2-2b the coupling is real: a sparse set of importance neurons predicts persistence at AUC 0.82, and amplifying those neurons ×3 causally roughly doubles it. In qwen2.5-14B and deepseek-r1-14B it does not replicate—deepseek scores R² −0.38 on regression and AUC 0.625 against a 0.628 random baseline. Yet deepseek is by far the most persistent behaviorally (median 51 attempts vs. 2 for gemma and 4 for qwen, with 32% filling the 32K context), consistent with a reasoning model whose persistence is driven by the <think> trace after the prompt—invisible to a single opening-prompt forward pass. |
|
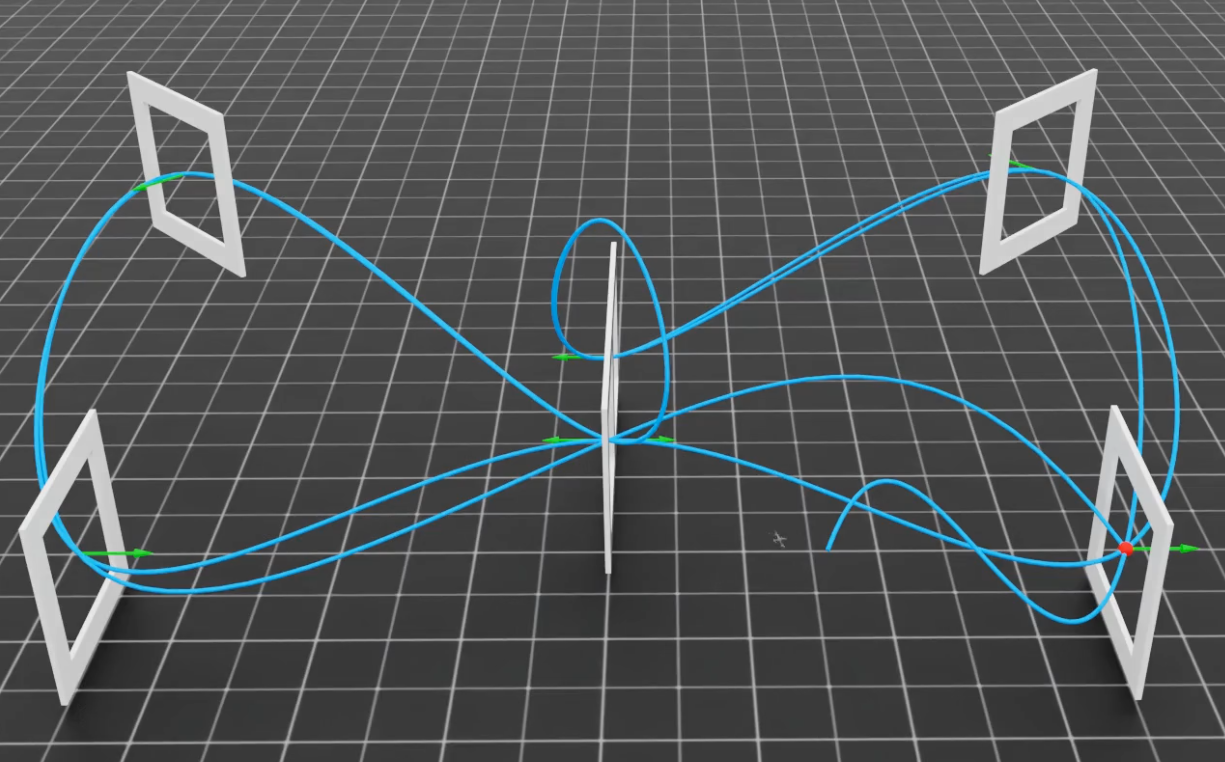
Autonomous Drone Racing with PPO
Jaime A. Romero ESE 651 Final Project, 2026 Implemented high-performance autonomous racing agent using Proximal Policy Optimization (PPO). Designed and iteratively refined reward shaping strategies—balancing gradual ramp-ups for track progress, gate passage, action continuity, and collision avoidance throughout training. Explored state estimation and integrated recurrent neural networks (RNNs) to improve policy performance. Also experimented with Soft Actor-Critic entropy stabilization methods to smooth reward transitions. Through extensive tuning and evaluation, achieved consistent lap times of approximately 18 seconds. [ Video Demo ] |
|
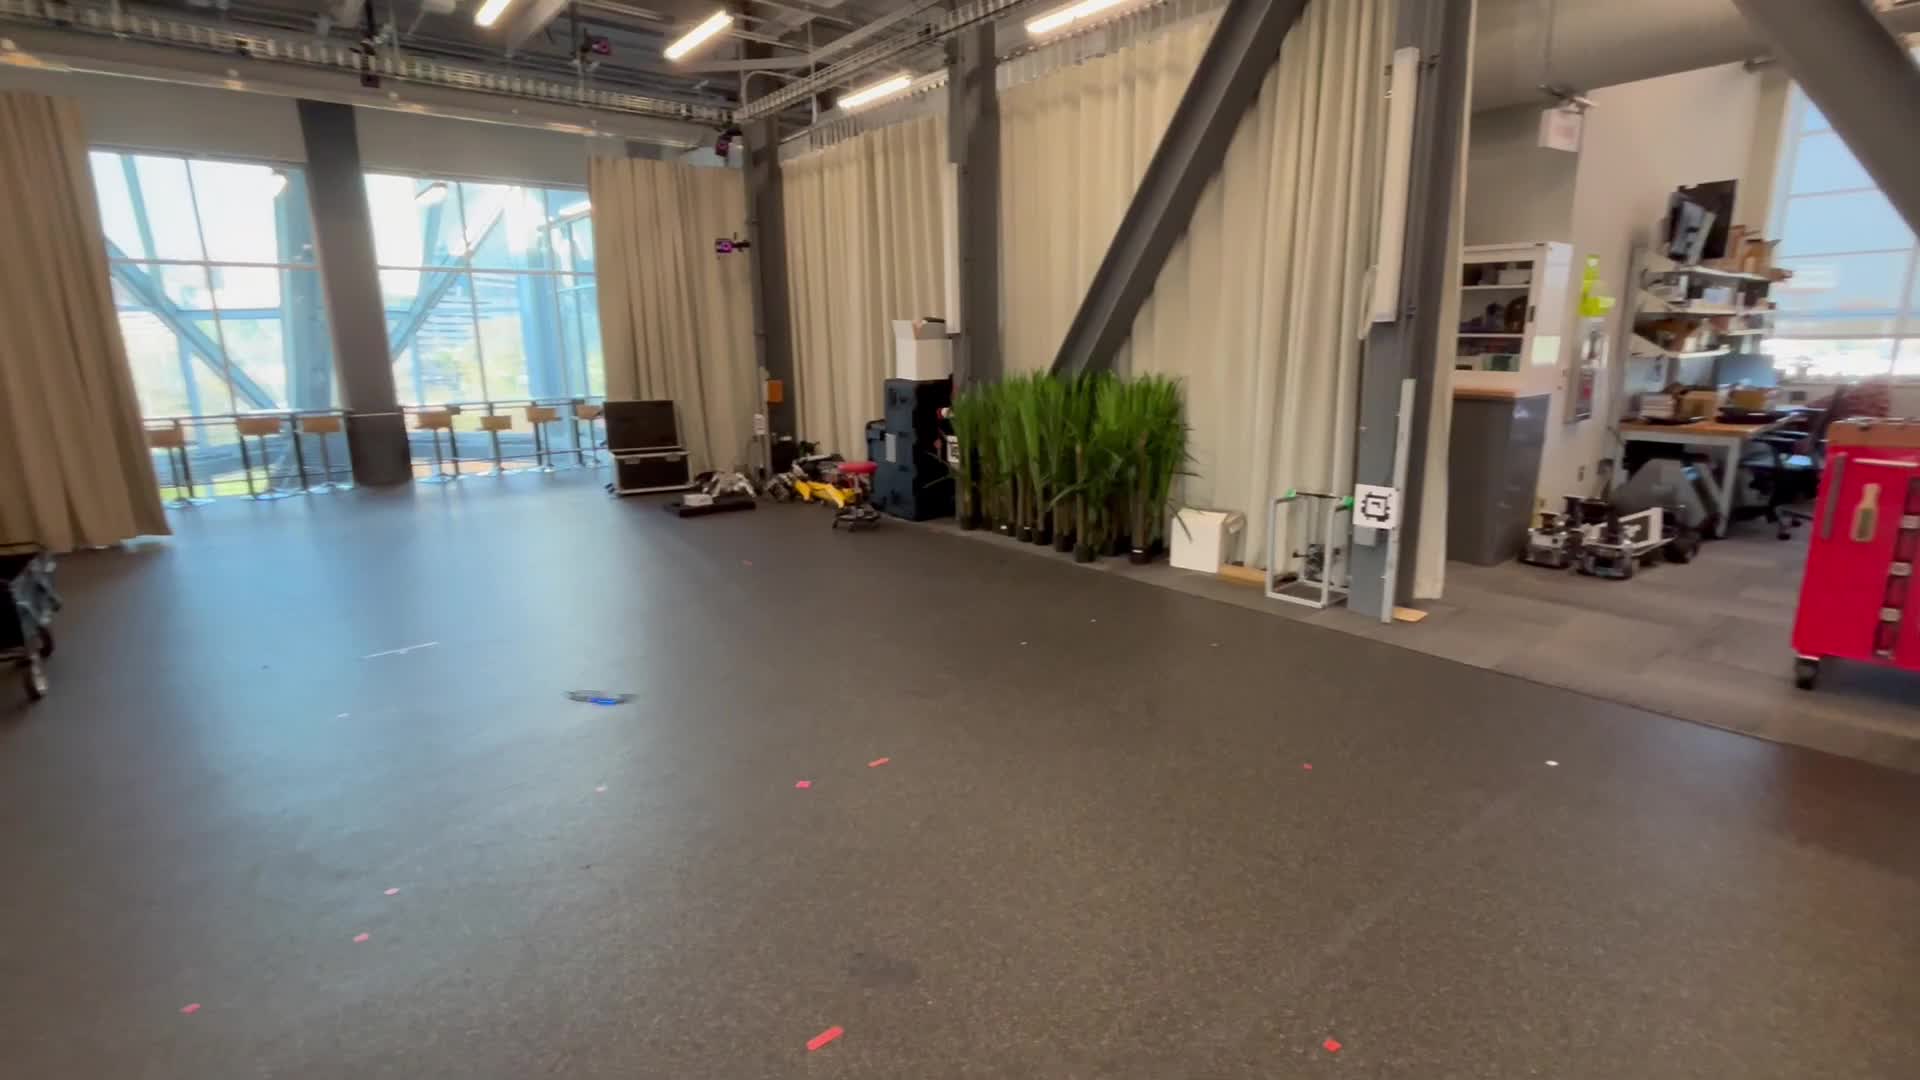
Sim-to-Real Drone Deployment
Jaime A. Romero Physical Intelligence Final Project, 2026 Investigated the sim-to-real performance gap between a drone trained in Isaac Lab and its real-world deployment. Conducted system identification and flight testing to compare simulated and physical behavior, identifying a consistent altitude offset of approximately one foot between environments. Developed calibration and control adjustments to compensate for the discrepancy and improve flight accuracy. [ Video Demo ] |
|
FlexBot Reverse Engineering and ROS Integration
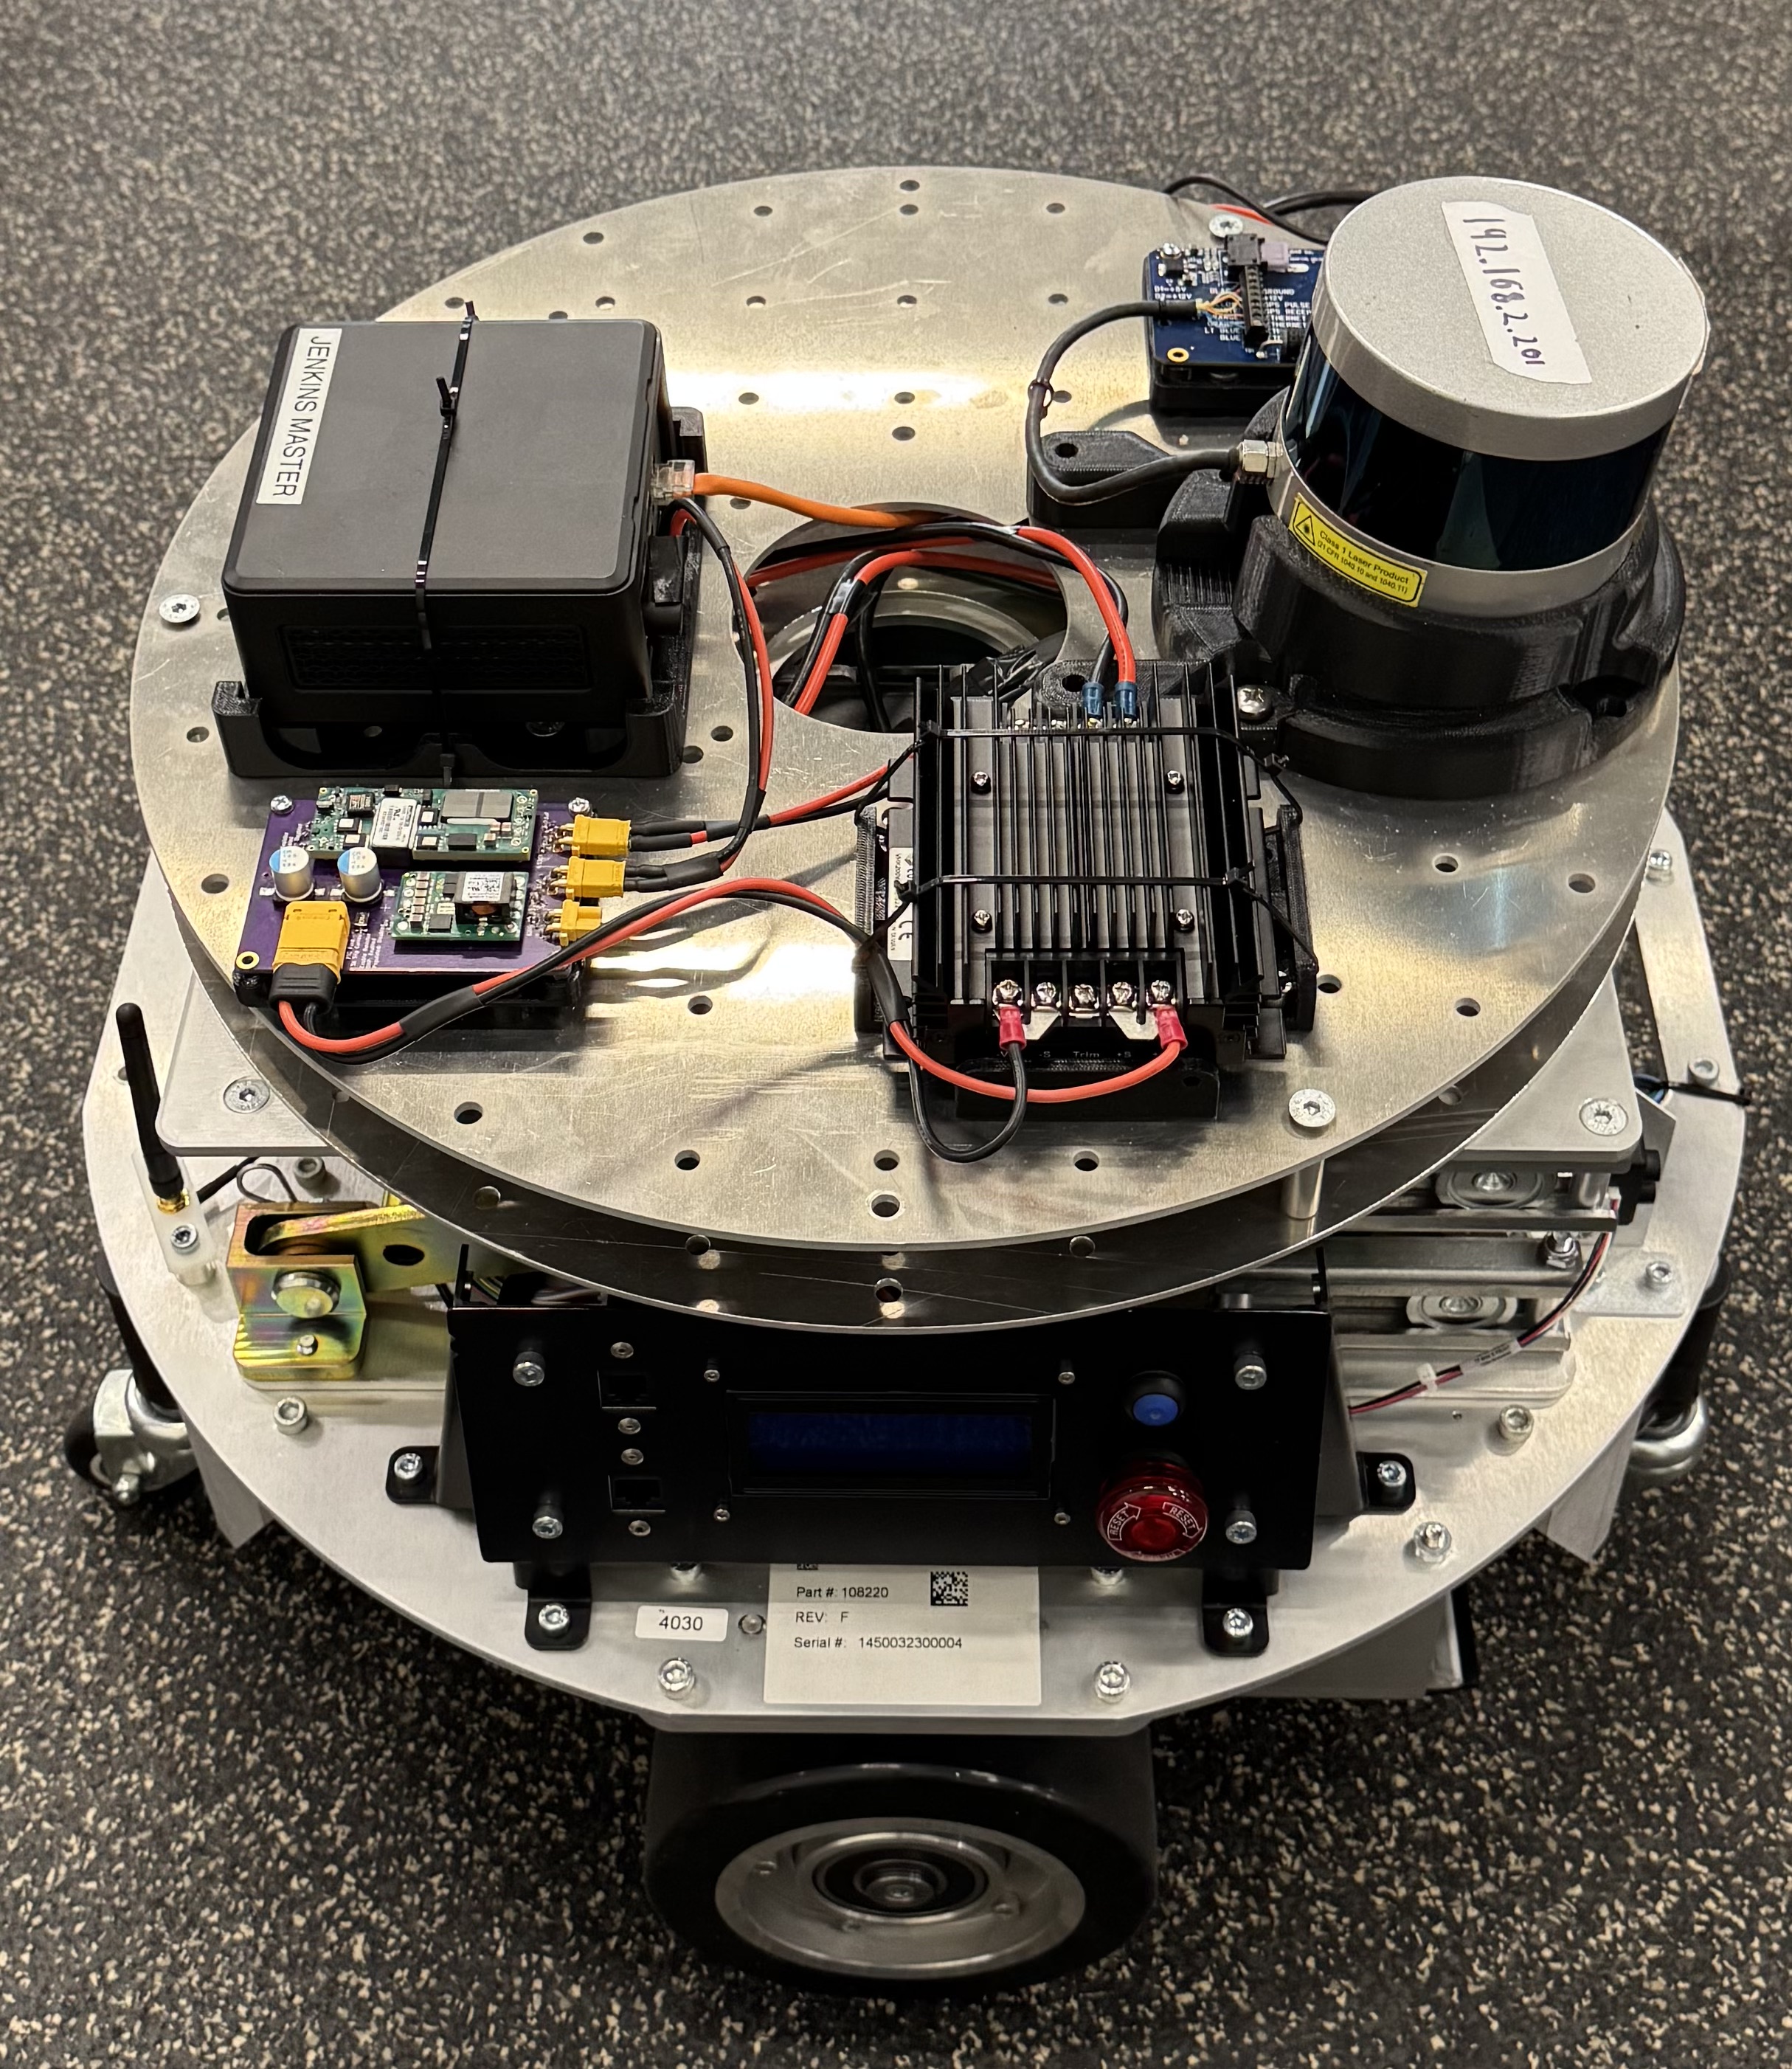
Jaime A. Romero GRASP Lab Capstone Project, 2026 Repurposed the FlexBot—a differential-drive industrial robot donated to GRASP by Berkshire Grey—as a general mobile platform for future robotics research and teaching at Penn. Documented hardware and electrical architecture, evaluated custom control software, removed application-specific hardware, and integrated new systems including LiDAR, an external computer, and an odometry pipeline. Integrated the completed system into ROS 2 for teleoperation, odometry, and SLAM, and produced documentation for future users and development. [ Video Demo ] [ GitHub ] |
|
McGeer's Passive Dynamic Walker Recreation
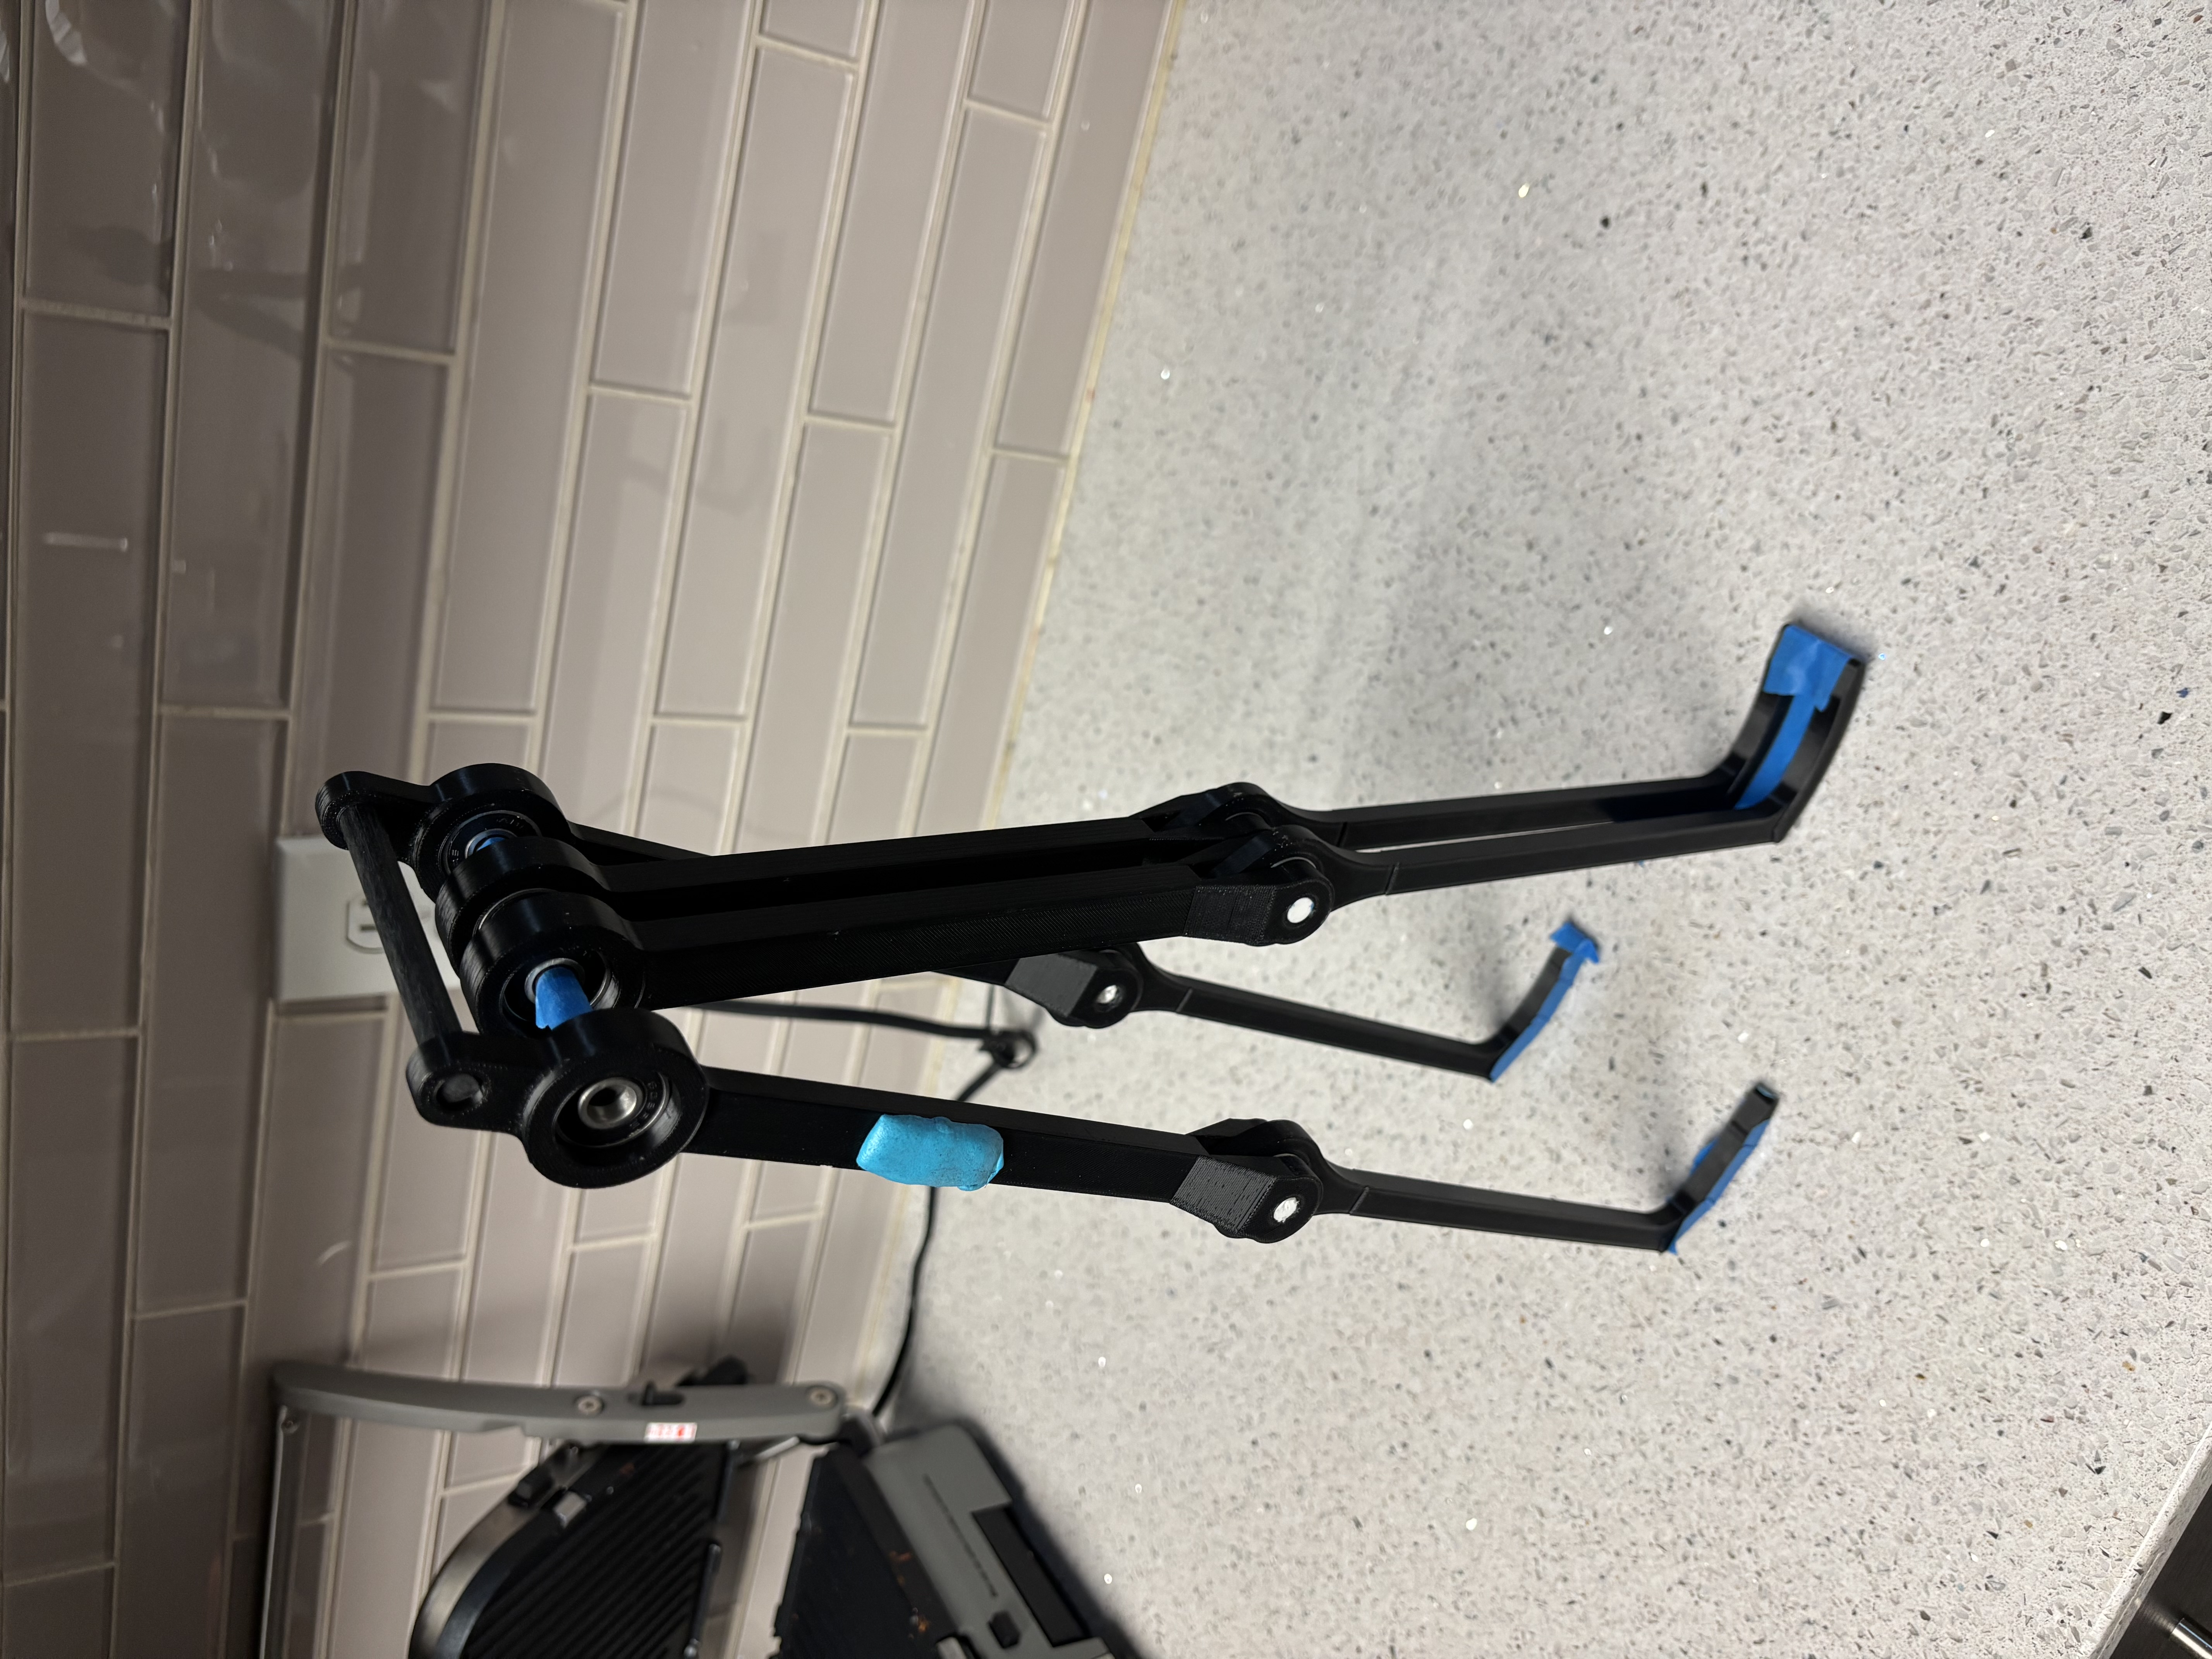
Jaime A. Romero Personal Project, 2026 Recreated McGeer's passive dynamic walker through simulation and physical prototyping. The simulation utilized a 3-link Ordinary Differential Equation (ODE) model, transitioning to a 2-link ODE with intermediate velocity calculations based on inelastic collision assumptions. |
|
Stacked Image Resnet to statespace Cartpole Implementation
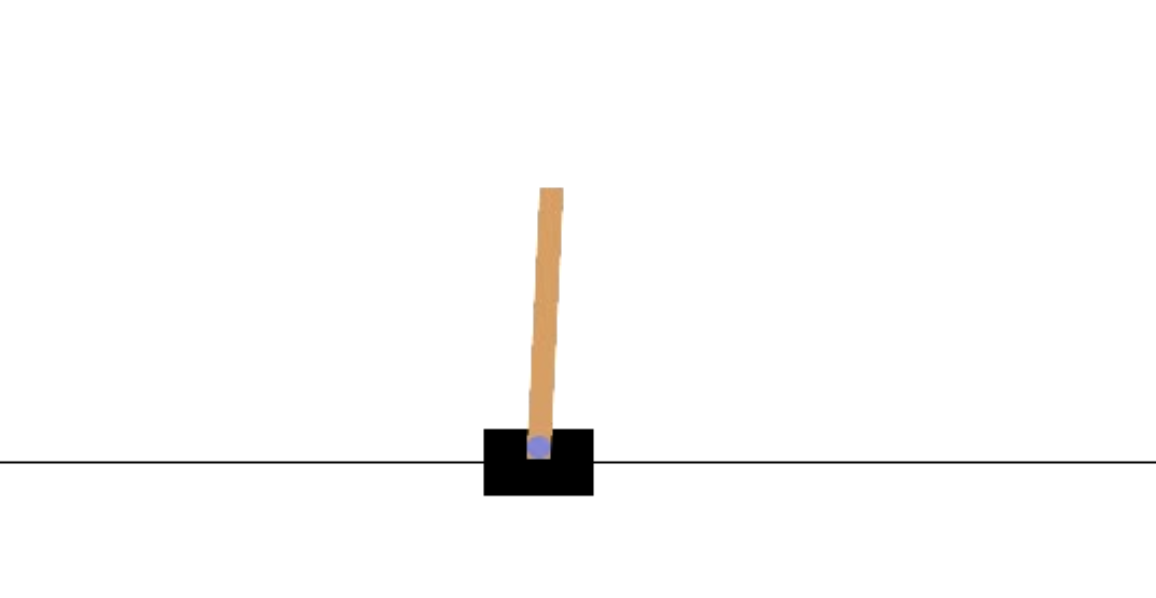
Jaime A. Romero 5200 ML Final Project, 2025 Trained cartpole on stacked gymnasium obs data using SAC. While training, collected images of env and paired them with the enviroment obs. Trained a Resnet to predict the stack of enviroment obs based on a stack of env images. Without finetuning our actor performed very well! [ Video Demo ] |

|
Nystag VR: Digital HINTS Exam Assessment
Jaime A. Romero Nystag LLC, 2024–2025 Developed a Unity-based VR system that replicates the HINTS neurological exam to evaluate eye movement for diagnostic purposes. Conducted market research and customer discovery through CMU I-Corps program to validate clinical applications. |
|
Autonomous Vehicle Fleet Management System
Jaime A. Romero General Motors, 2024–2025 Built an in-house mobile fleet management system reducing routing and monitoring task times by ~80% and increasing data diversity by 13%. Deployed an image classification model (97% sensitivity, 96% specificity) for obstruction detection, improving fleet collection efficiency by ~6,800 hours/year. |
|
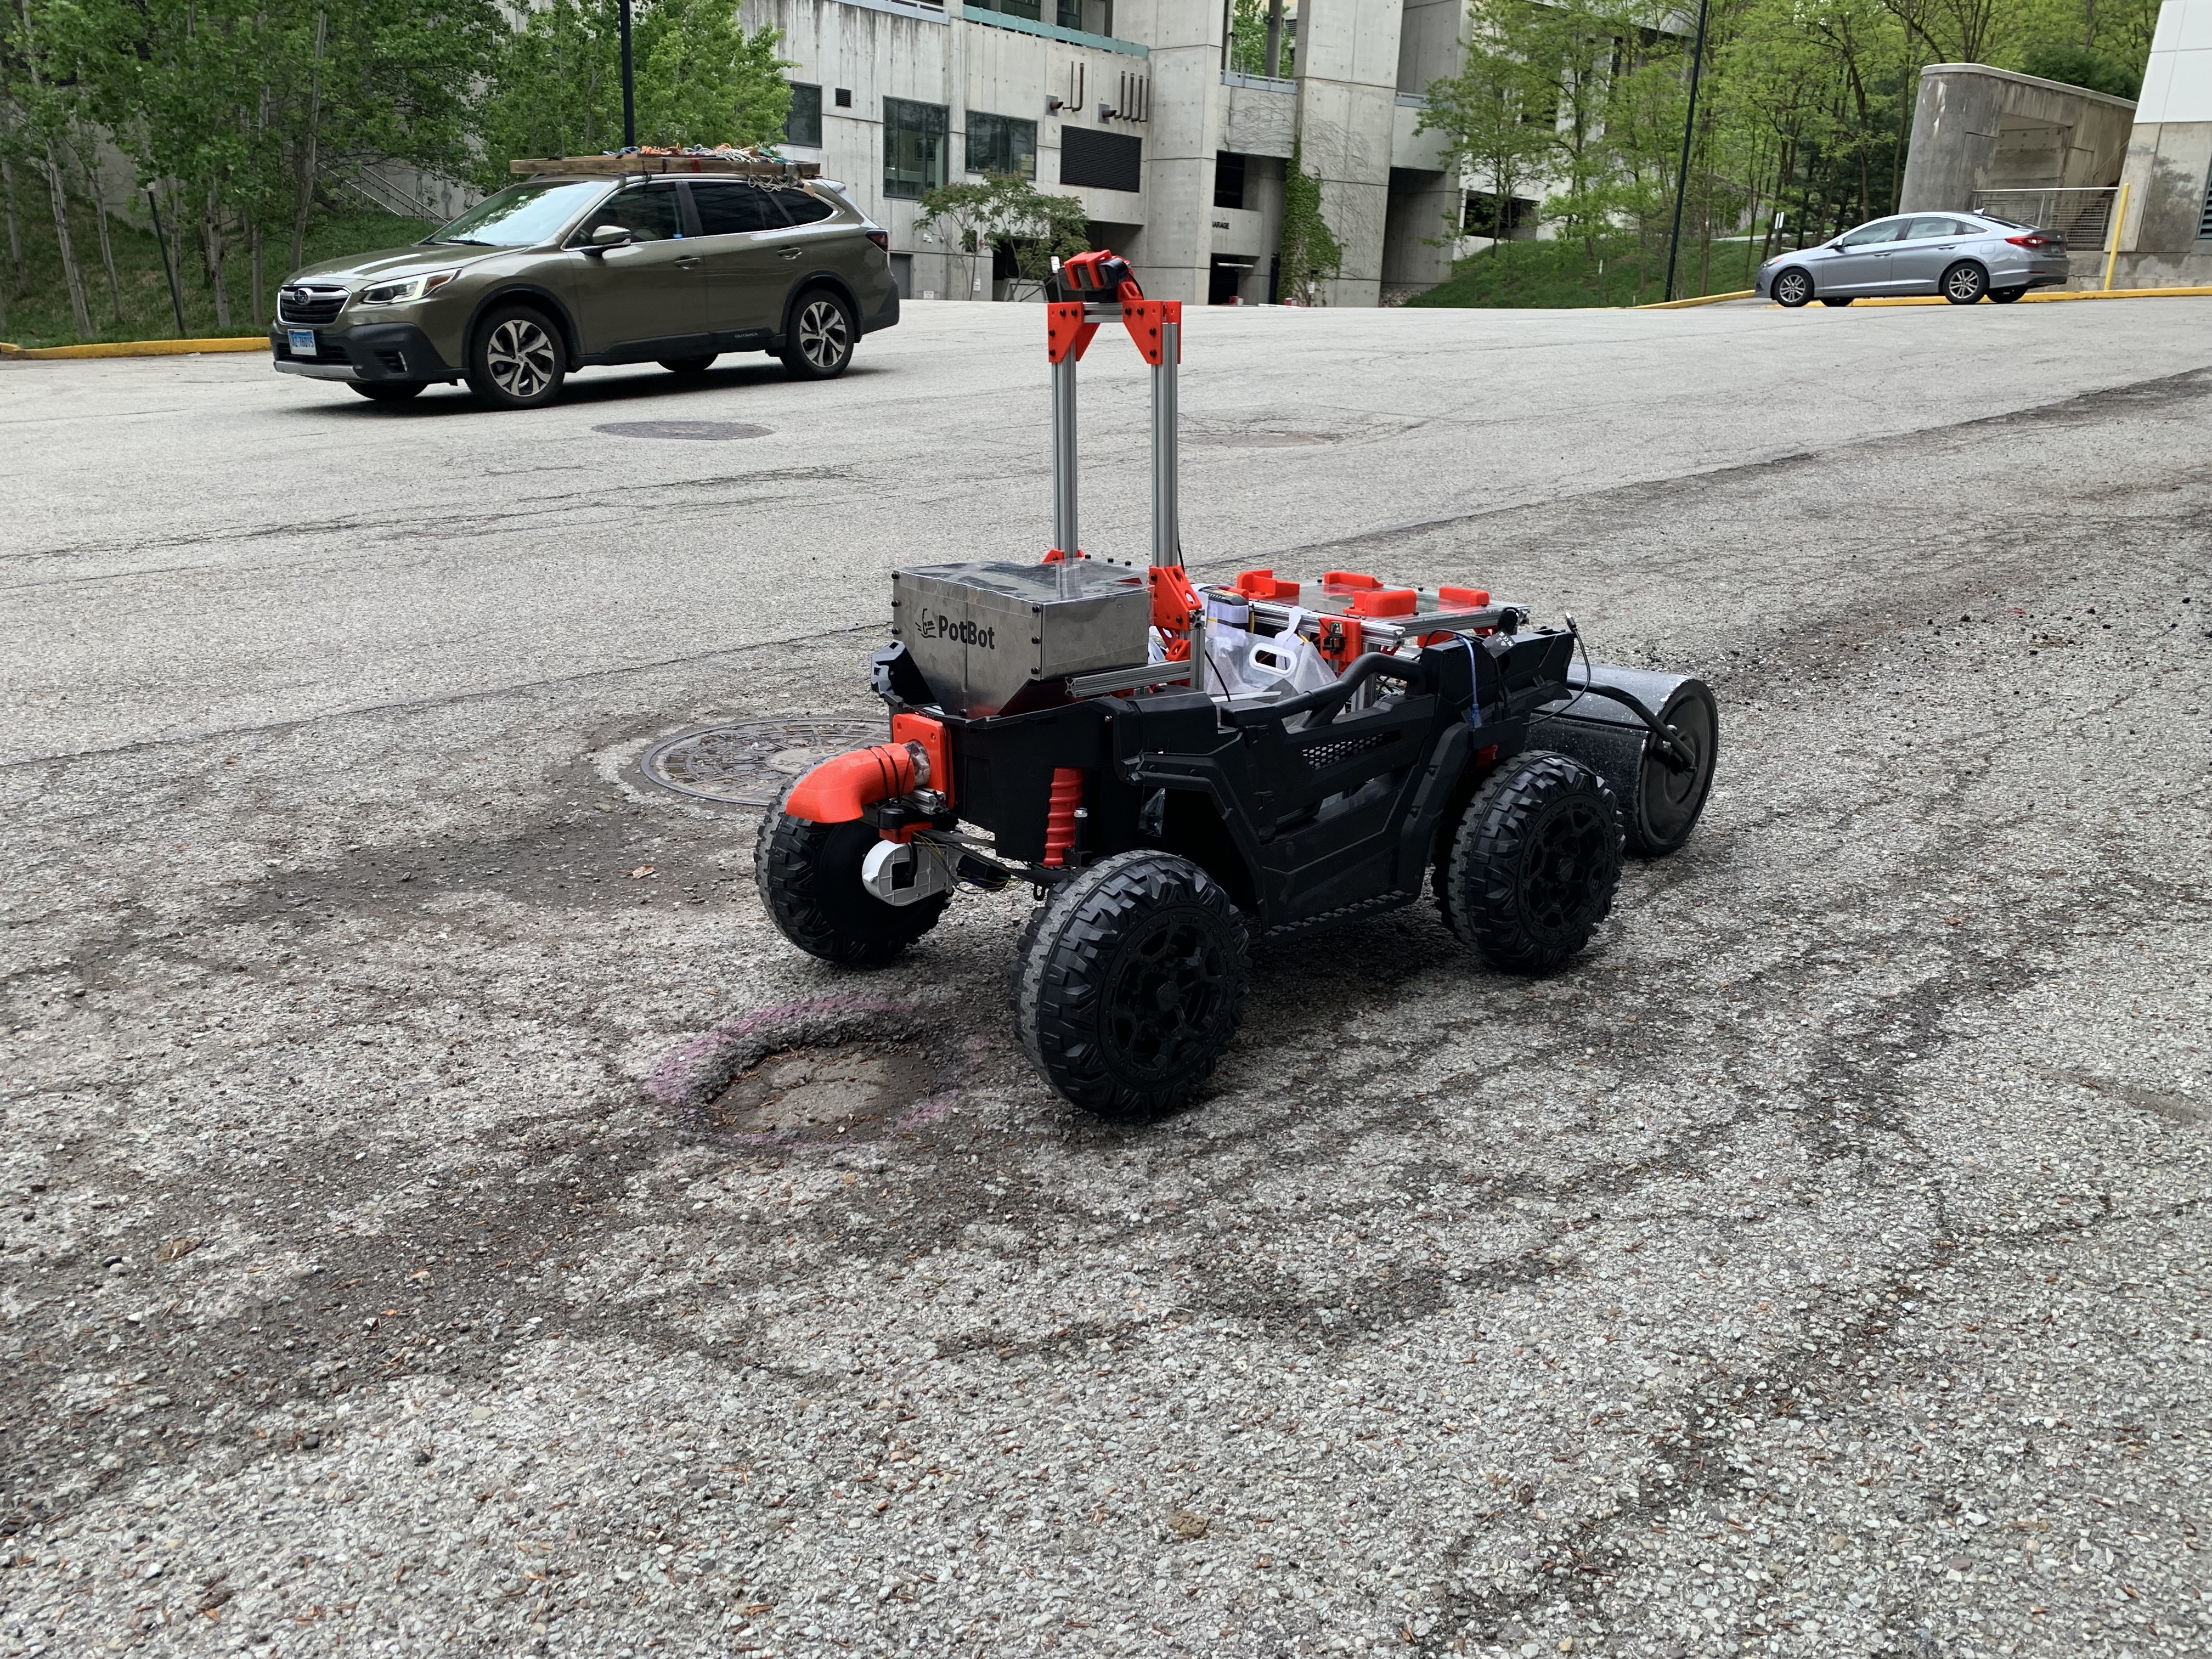
Autonomous Pothole Filling Robot
Jaime A. Romero CMU Senior Capstone, Spring 2023 Trained YOLOv5 object recognition model for road markings and defects (potholes, manhole covers, traffic cones). Developed a self-labeling pipeline with human-in-the-loop supervision to create the largest open-source pothole dataset. Designed integrated system architecture for autonomous navigation and pothole filling. |

|
Social Navigation Test Bench
Jaime A. Romero CMU BIG Robotics Lab, Summer 2022 Designed evolutionary-learning-based algorithms for agent demographic selection in crowd simulation. Modeled pedestrian movement patterns using statistical analysis to improve robot navigation in human environments. |
Experience
Autonomous Vehicles Fleet Systems SWE
Hydraulic Controls Group Product Engineer
Electric Motors Intern
Research Assistant |
Education
University of Pennsylvania
Carnegie Mellon University Relevant Coursework: Deep Reinforcement Learning, Graph Neural Networks, Linear Controls, Machine Learning, Machine Perception, Physical Intelligence |
Technical Skills
Programming: Python, C++, MATLAB, SQL, Linux |
|
Last updated: June 2026 | Design from Jon Barron's website |